







I work where firmware meets robots — MCU drivers, RTOS and DSP on one end, robot-arm control, VLA policy deployment and edge NPU inference on the other.
中文简介
中山大学电子与信息工程学院(SEIT)学生。关注嵌入式与机器人:一端是 MCU 驱动、RTOS 与信号处理,另一端是机械臂控制、VLA 策略部署与端侧 NPU 推理。
|
STM32-accelerator · black-box circuit learner
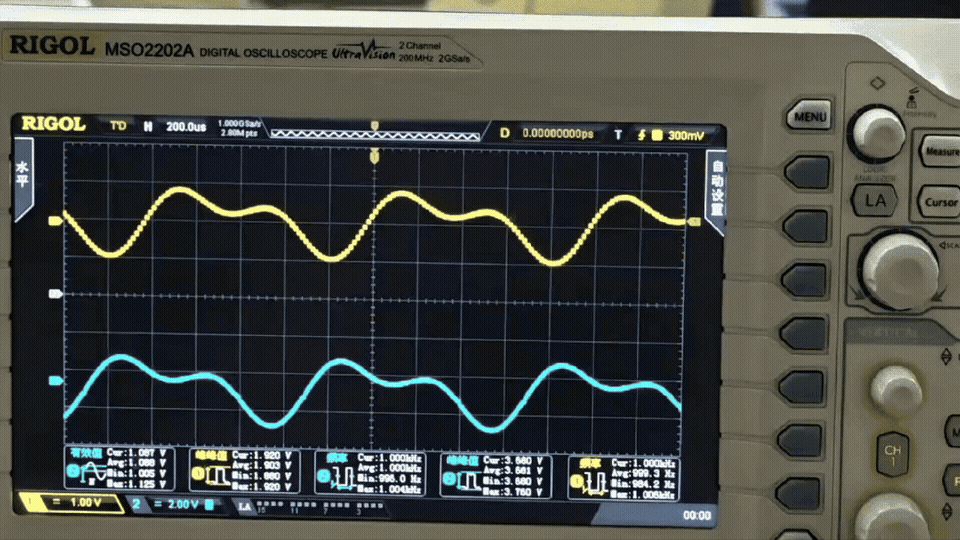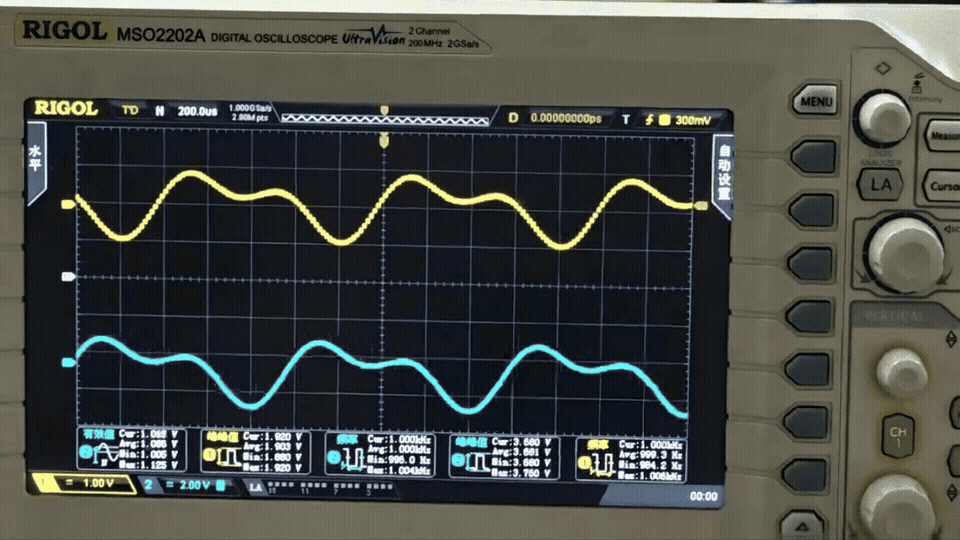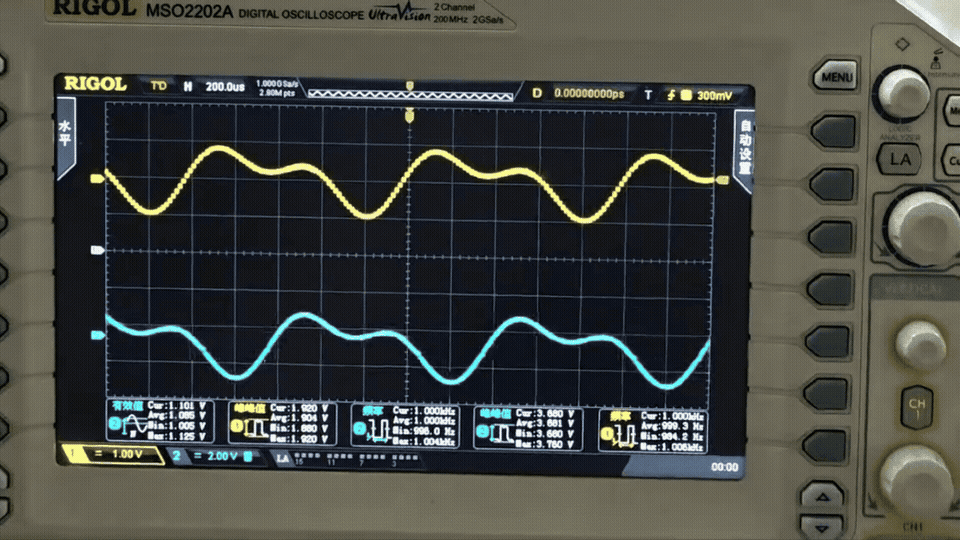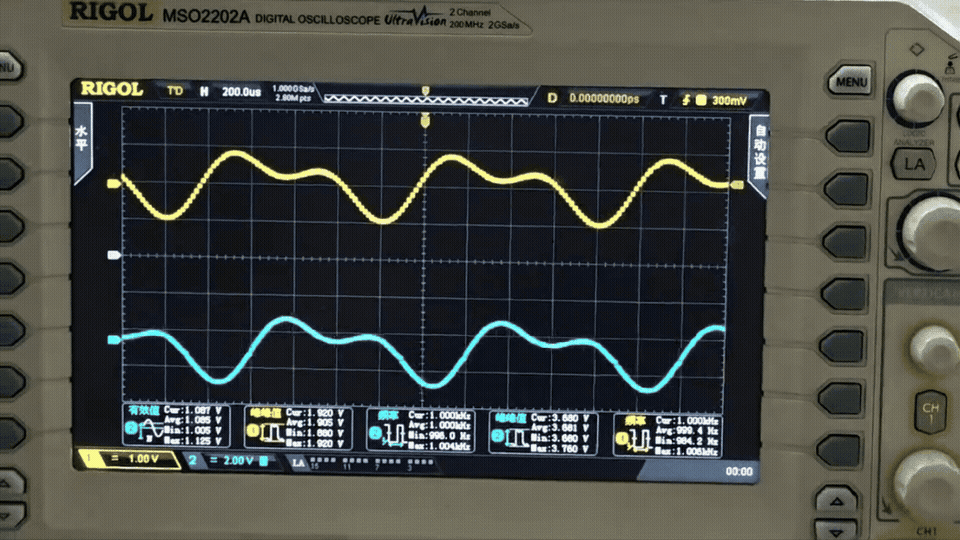
2025 NUEDC, signal track, problem G STM32H750 system that sweeps an unknown circuit with an AD9954, samples input and output on synchronized dual ADCs, identifies its frequency response via FFT and reconstructs time-domain waveforms in real time. 


|
|
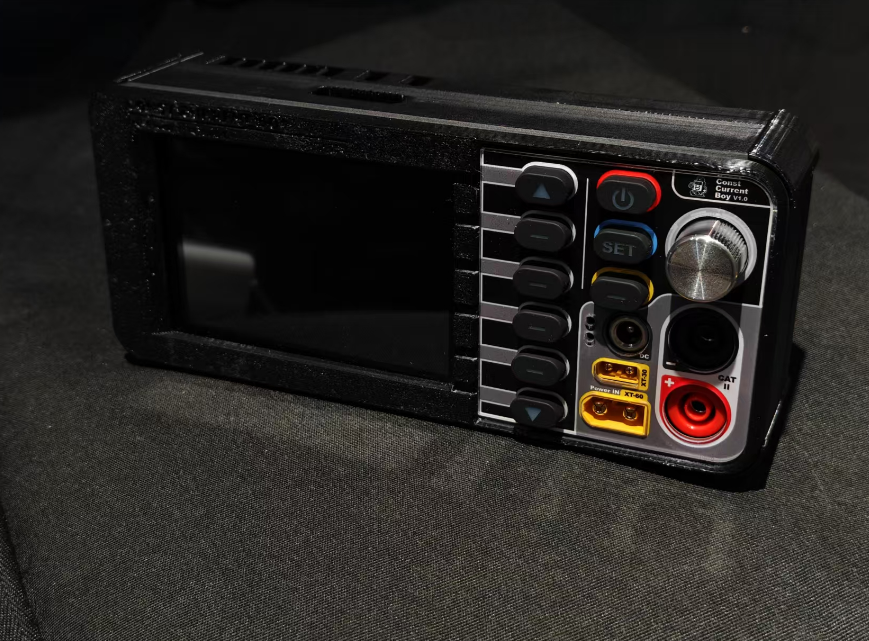
ELEVOURER · ESP32-S3 electronic load
SYSU SEIT engineering practice course Portable smart electronic load with CC / CP / CR modes, real-time power monitoring and a touchscreen GUI. 


|
|
|
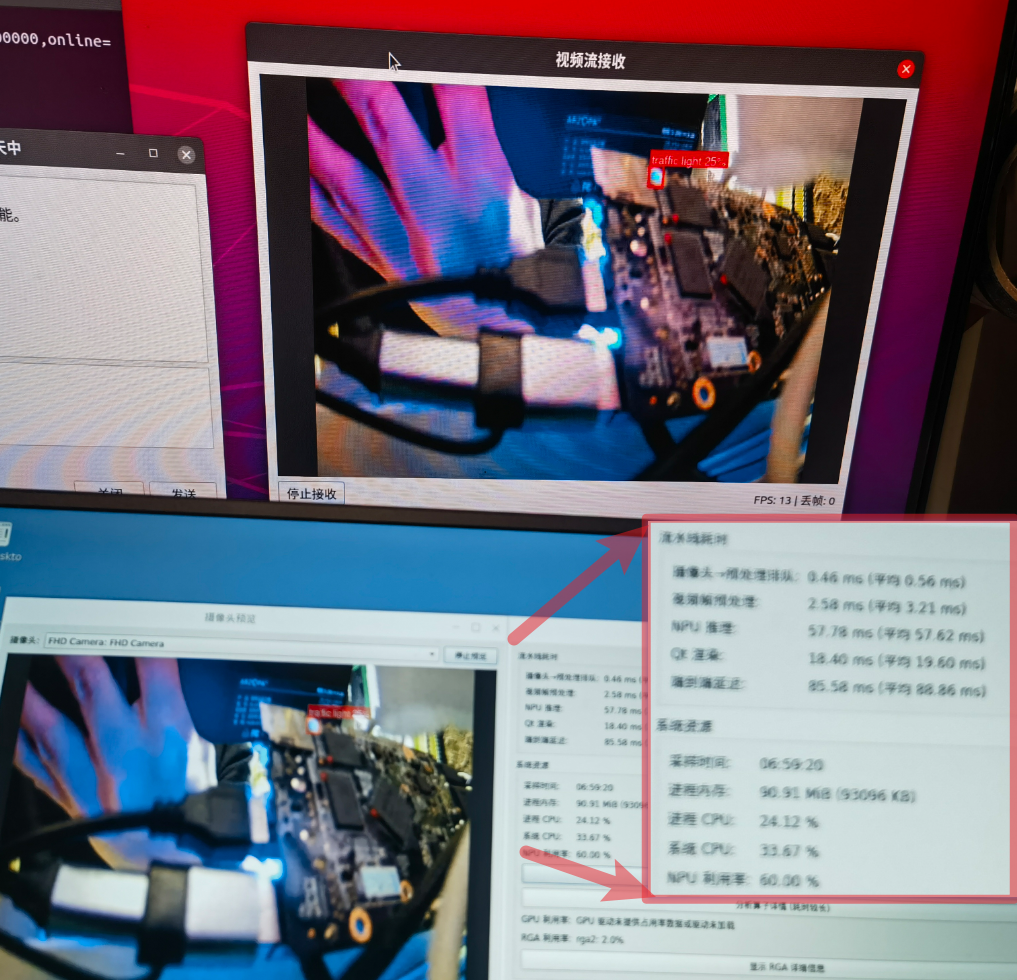
KyLink · edge messaging & video on RK3566
Embedded Linux · on-device AI LAN messaging (FeiQ protocol), GStreamer video streaming and RKNN NPU detection on RK3566 + Ubuntu Kylin, plus a board-level LED driver. 


|
|
armctrl
Robot arm · control & SysID Control and system-identification shell for the ARX5 arm: safety gates around planned motion, bounded agent action recipes and SysID orchestration. 


|
embegent
Agent harness · MCU debugging Agent-friendly harness for on-target STM32 debugging: structured state, evidence and context layers so a coding agent can run long debug sessions reliably. 


|
More projects
| armodel Python · VLA · NPU |
Model-side workspace for the arm stack: smoVLA post-training, export and NPU inference runtime |
| Linky C · Linux |
Lab for low-latency buffer ownership: buffer pools, memfd and DMA-BUF with descriptor rings, measuring tail latency |
| final-tracker C++ · ROS1 · MuJoCo |
Target-tracking UAV workspace: MuJoCo quadrotor bridge, UAM controller, perception, mapping and planning |
| Gesture-DetectionRecognition Python |
Camera-based gesture detection and recognition |
| PID-Lambda-param-tuning MATLAB |
PID tuning with the Lambda method |
| Languages | |
| Embedded | STM32 ESP-IDF FreeRTOS LVGL CMSIS-DSP FOC Modbus |
| Robotics & AI | MuJoCo LeRobot Pinocchio RKNN ONNX |
| Tools |

